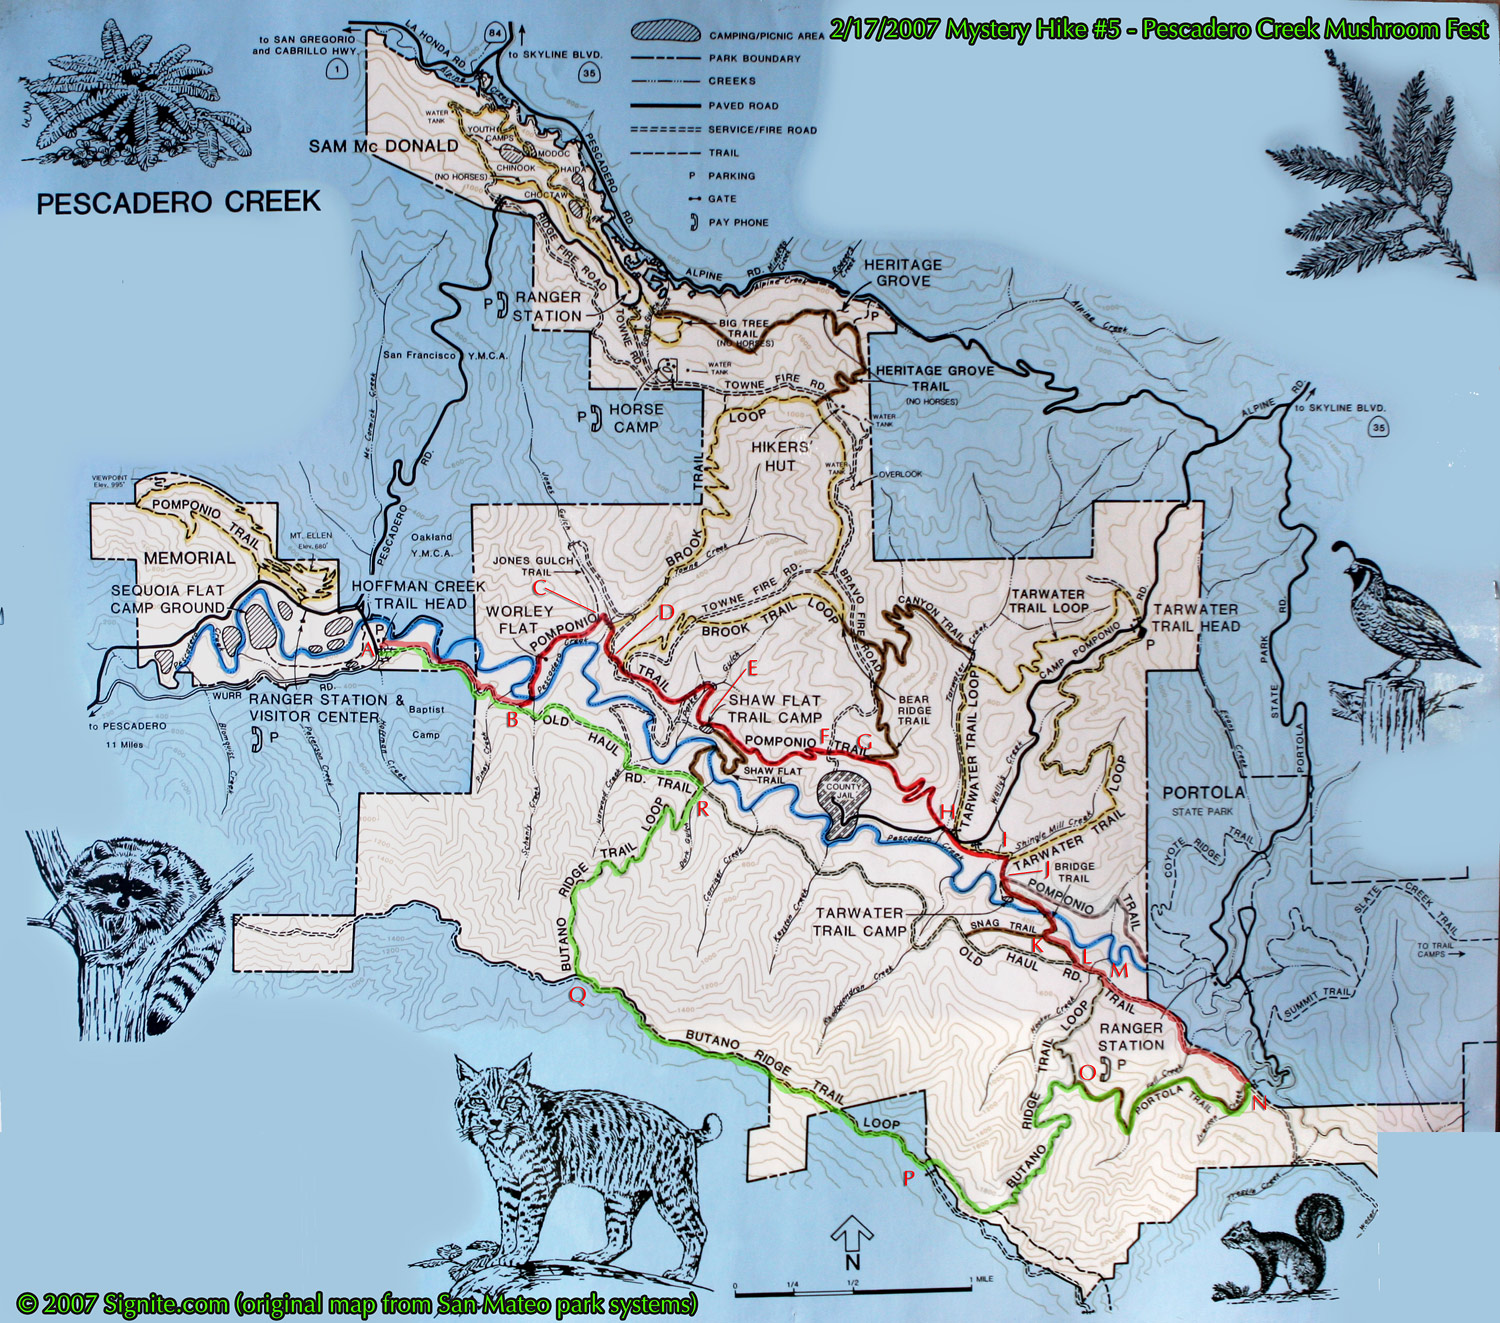
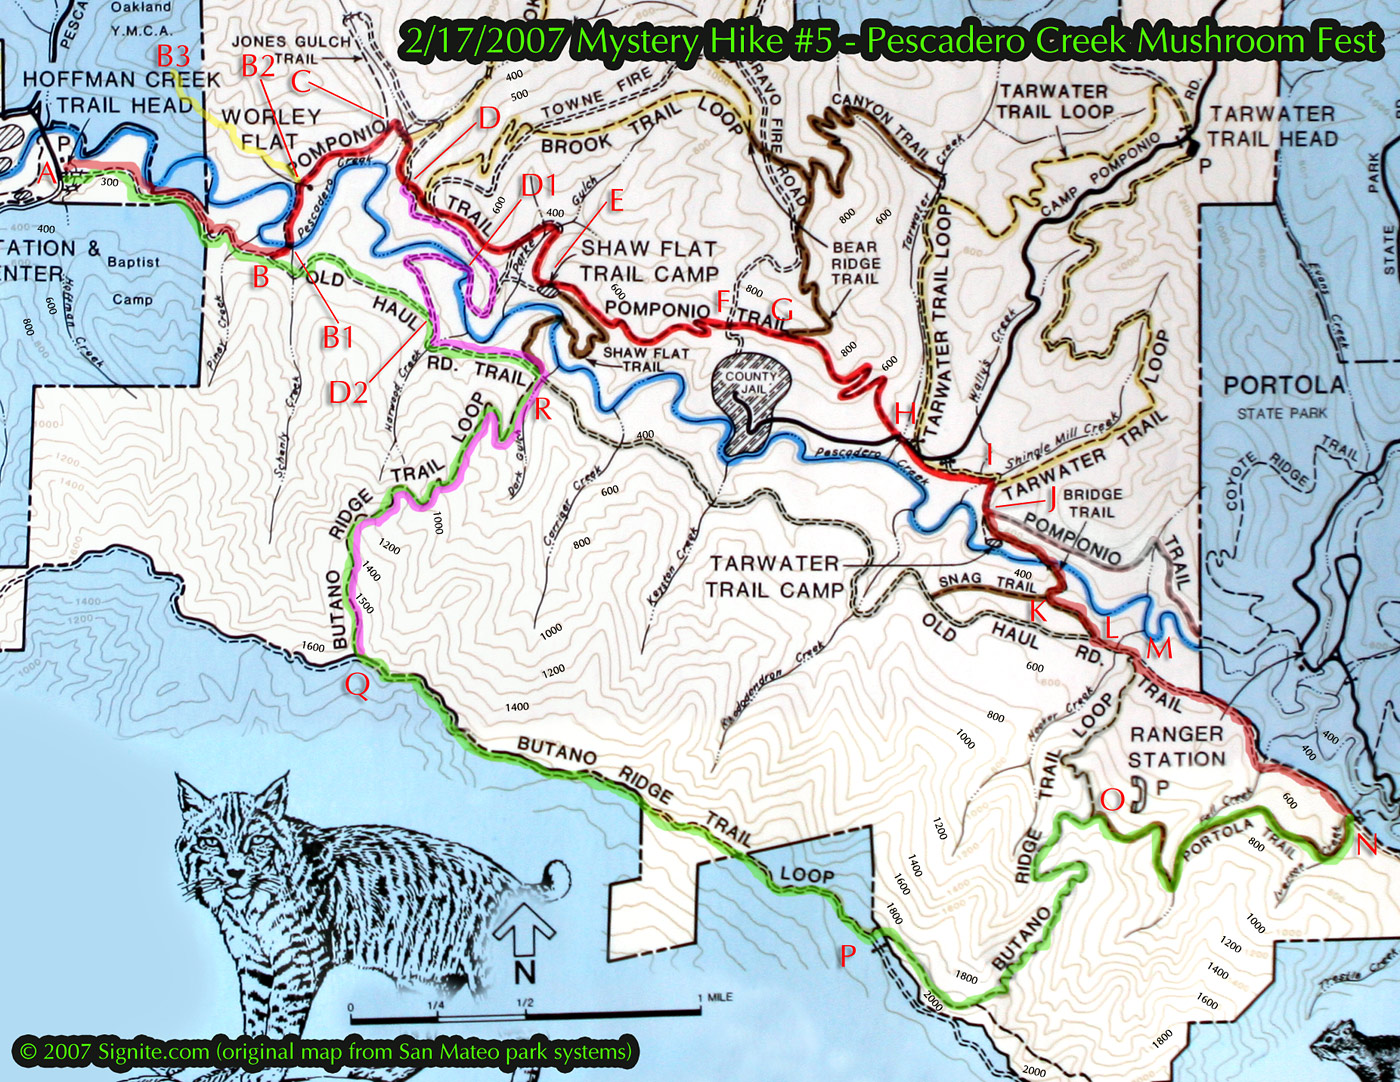
The following is map of the actual path (A-B-B1-B2-B3-B2-C-D-D1-D2-R-Q-R-D2-B-A):
The following is map of the planned path: